
Micropartner




Features
- Maks. keliamoji galia: 125 kg
- Maks. darbinis spindulys: 2800 mm
- Vertikalus pakėlimas: 2450 mm
- Darbinis slėgis: 0.7 ÷ 0.8 Mpa
- Valdymo sistema: tik suslėgtasis oras
- Tiekimas: filtruotas suslėgtasis oras (40 µm), be alyvos
- Triukšmo lygis: <70 dB
- Maks. kėlimo greitis vertikalia kryptimi: 0,5 metro per sekundę
- Darbinė temperatūra: nuo +0 °C iki +45° C
- Sąnaudos: nuo 50 Nl iki 100 Nl per darbinį ciklą
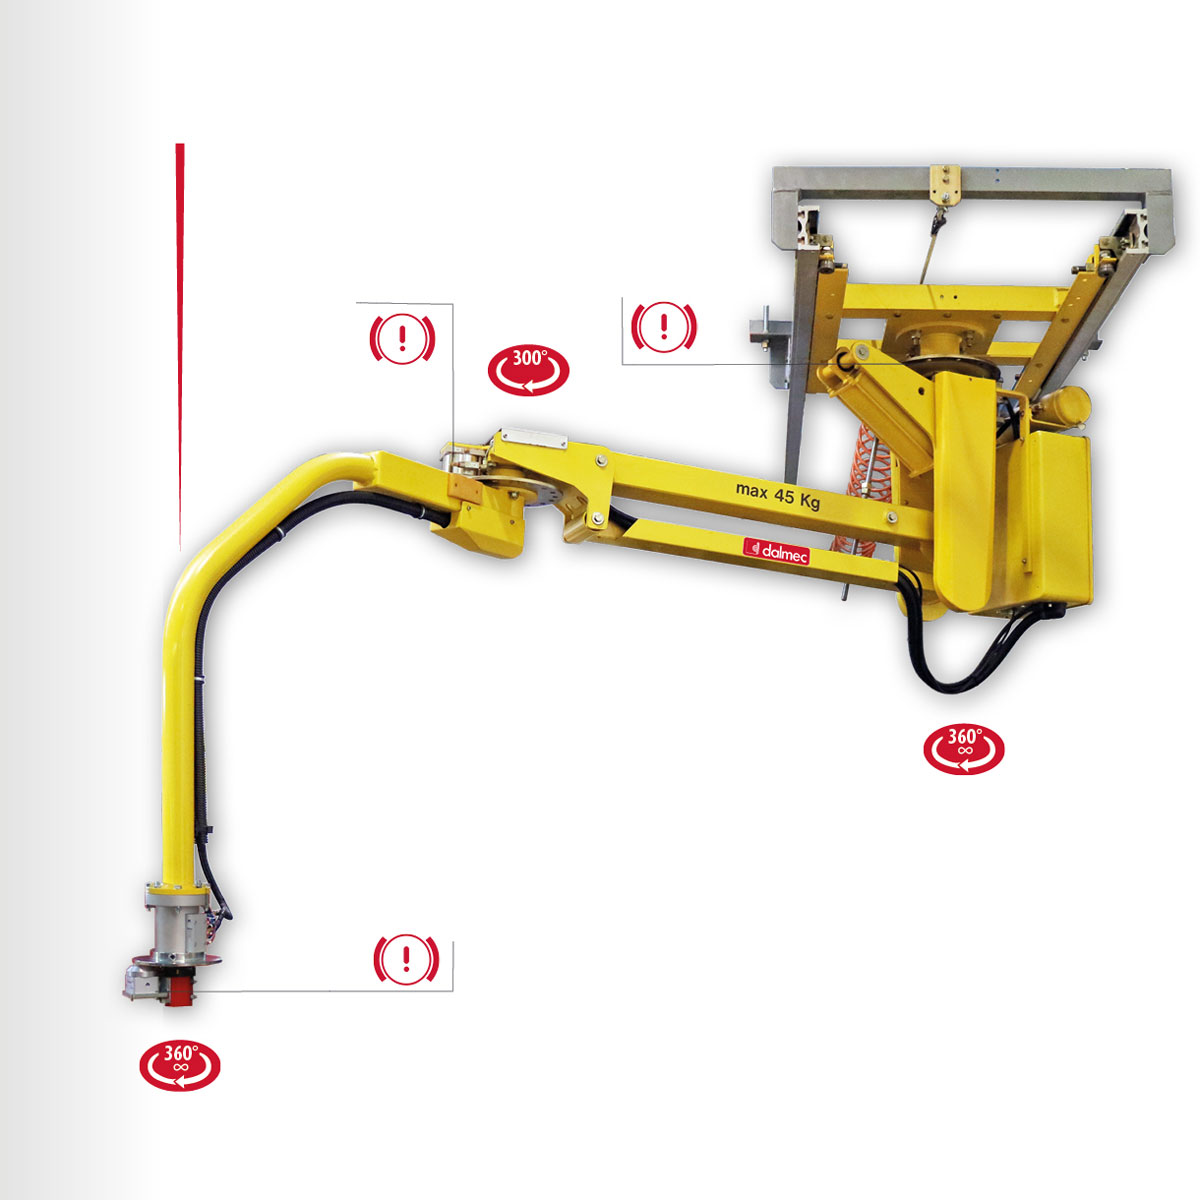
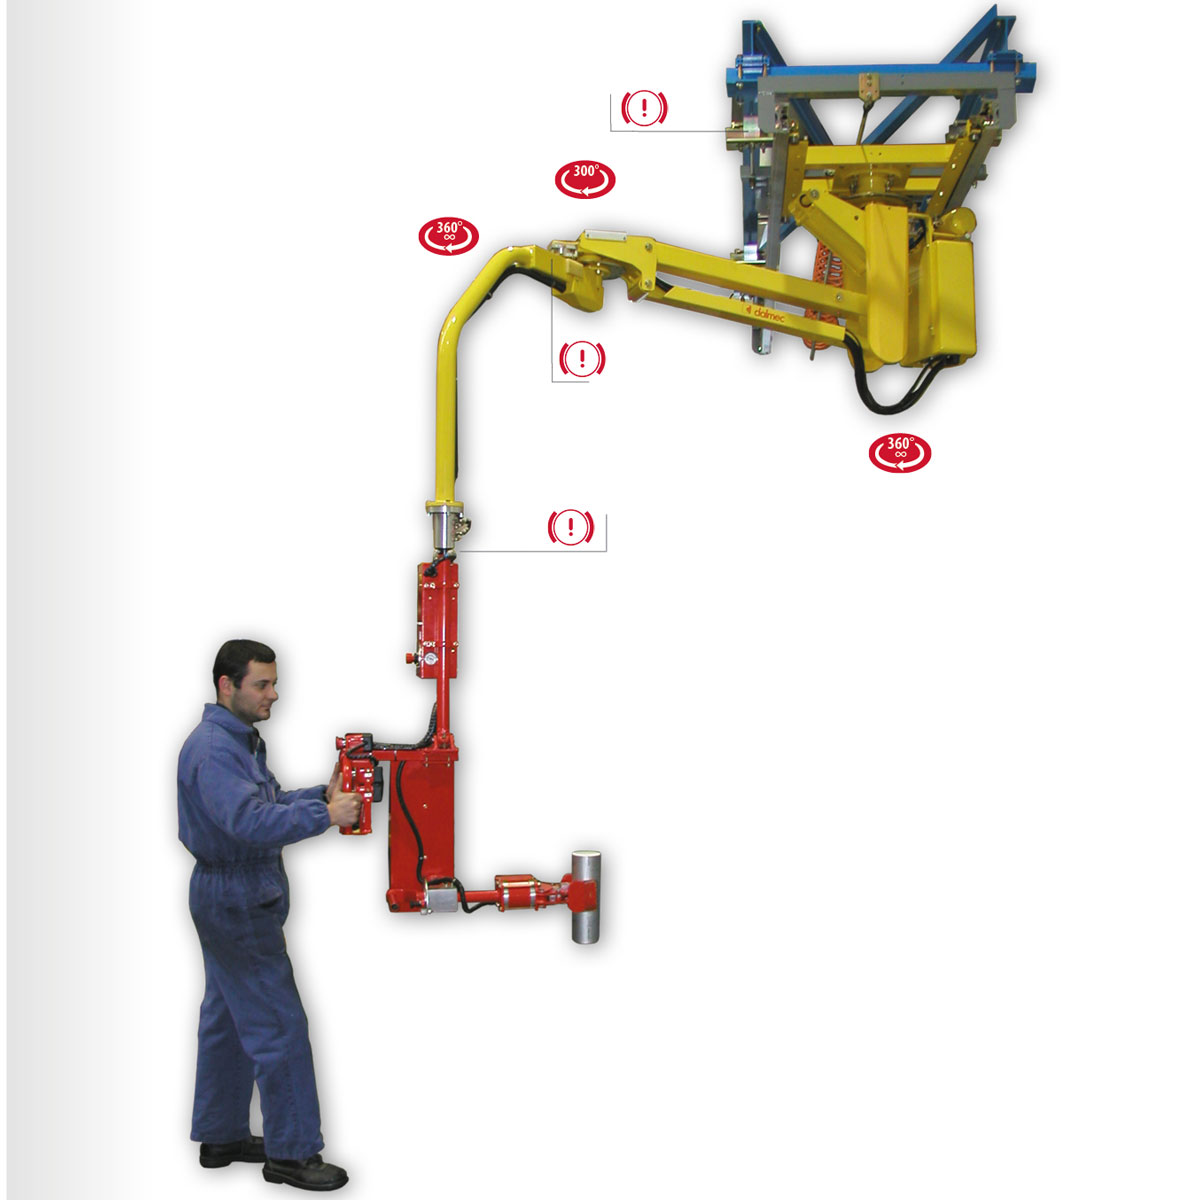
- Sukimasis: – nuolatinis 360° ant kolonos ir įrankių ašies – 300° ant tarpinės ašies
Execution
- ATEX fiksuotas viršuje
- ATEX judantis viršuje
- ATEX kolona
- Fiksuotas viršuje
- Judantis viršuje
- Kolona
- Nerūdijančio plieno fiksuotas viršuje
- Nerūdijančio plieno judantis viršuje
- Nerūdijančio plieno kolona
MANIPULATOR MICROPARTNER WITH ARTICULATED ARMS
Thanks to the reduced dimensions, the MICROPARTNER MI is a lifting device particularly easy to handle, designed to move in a weightless condition medium-light, center and off-set loads in any direction. Equipped with special gripping tools it allows the operator to work quickly, with precision and without effort, in excellent ergonomic and safety conditions.


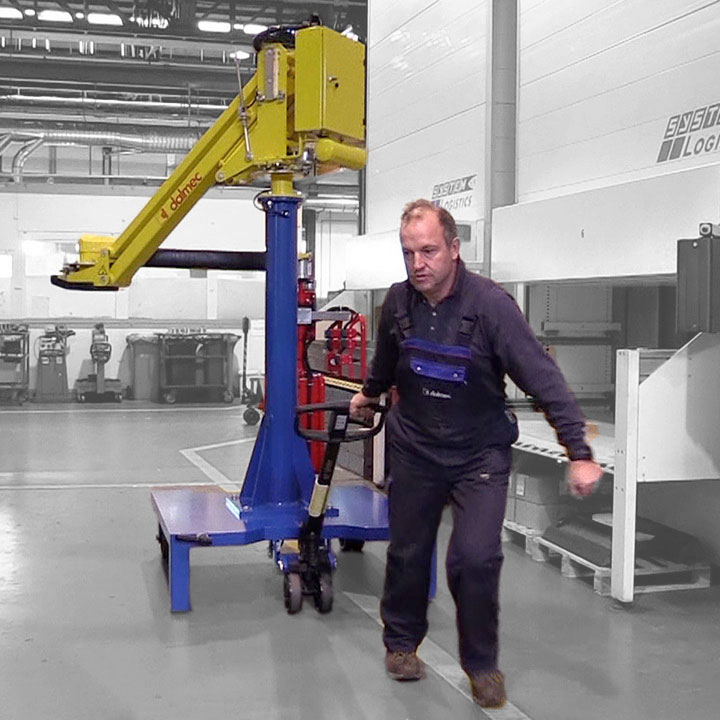
| Fixed plate for floor anchoring | Autostable base-plate for forklift truck | Autostable base-plate for pallet truck |
 |  |  |
| Manual autostable base-plate | Trolley mounted base-plate | Floor built-in track |
 |  |  |

Anchor flange
The pneumatic manipulator fixed overhead version allows to eliminate any floor obstructions.
The flange of the Manipulator is supplied with holes for the anchoring with screws to a strong plate to the ceiling or to a shelf.
All movements are free and are obtained with minimum effort by the direct action of the operator on the gripping tooling or on the load.

Anchor
The Manipulator is supplied with an overhead trolley to run in a tracking system.
Tracking system
The tracking system is composed of two opposite aluminium U sections with connecting and stiffening ribs,complete with attachment points for an overhead suspension and end buffers. The junction between the various parts is done with screws.
Attachment
The attachment of the tracking system to the supporting structure is carried out by means of rods and suspension brackets